ACC – Acceleration Time
Gets/sets the acceleration [value] for [axis].
Access: Read/Write
Category: Motion
Applies to: All Commander Controllers
ASCII/Standalone ACC global acceleration setting
ACC[axis] individual axis acceleration setting
Syntax
Read
ACC[axis]
|
[axis] is set to X, Y, Z, U, or not specified to affect all axis |
Write
ACC[axis]=[value]
|
[axis] is set to X, Y, Z, U, or not specified to affect all axis [value] acceleration time is set to X, Y, Z, U, or not specified to affect all axis |
Reply
Command is accepted and executed
Read
ACC Returns the ACC parameter entered (acceleration time in ms)
Write
OK
Command cannot be processed
An error message is returned. See Error Codes
Example
Read
ACCX * Returns acceleration time set for the X axis in ms
Write
ACC=300 * Sets acceleration time to 300 ms for all axes
Notes
- If DEC is set to 0, then ACC setting is used for Acceleration and Deceleration time.
- Acceleration time should be no less then one half of deceleration time.
- Acceleration is time entered in milliseconds. Acceleration rate in pps2 (pulses/second2) can be calculated with the following formula:
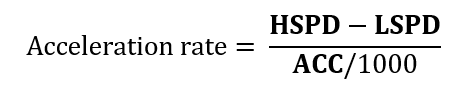
- The minimum and maximum acceleration values depend on the high-speed and low-speed settings. Refer to Speed Settings for details.
- Individual acceleration settings will take priority over the global acceleration settings. The global acceleration setting will only be used when one of the following conditions is true:
- The corresponding individual acceleration setting is defined as zero
- A coordinated motion is being performed
In the example below, the settings will set both the global speed settings and the individual speed setting for the X axis.
HSPD=10000
HSPDX=2000
LSPD=300
ACCX=500
ACC=300
DEC=300
Once a move command is issued in this example, the global speed settings for the low speed and deceleration, and the individual X-axis speed settings for the high speed and acceleration, will be used for motion.
See also
DEC, HSPD, JKA, JKD, LSPD, PS, SCV, SSPDM
Commander Manual
B.1 Acceleration/Deceleration Range
B.2 Acceleration/Deceleration Range – Positional Move