2.4 On-the-fly-speed/target position change
Commander controllers support the ability to change the moving speed and/or the target position on the fly.
In this section
- On-the-fly Speed Change
- On-the-fly Target Position Change (Target position change)
On-the-fly Speed Change
This function can change the speed while an axis is in motion, at any point in the motion profile. The figure below shows a few examples of how speed changes are executed.
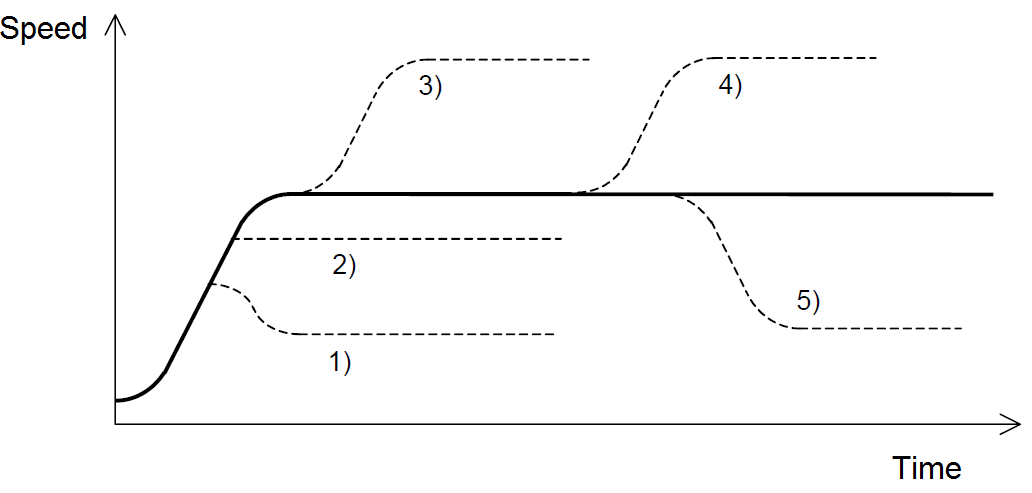
If the target speed is changed during the acceleration process, and:
- If the newly set value is lower than the pulse rate at the time of the change, deceleration is made to the newly set value.
- If the newly set value is equal to or higher than the pulse rate at the time of the change but less than the previous target, acceleration is made to the newly set value.
- If the newly set value is greater than the previous target, acceleration is made to the preset pulse rate and then to the newly set value.
If the target speed is changed while traveling at the previously set target speed:
- If the new value is higher than the previous target, acceleration is made to the newly set value.
- If the new value is lower than the previous target, deceleration is made to the newly set value.
On-the-fly speed change can be achieved using the SSPD[axis]=[newspeed] command. Before executing an on-the-fly speed change, ensure the correct speed range is set with the SSPDM[axis] command. For more information on the speed range setting, see Appendix B: Speed Settings and SSPDM in the command reference.
|
ASCII |
||
|
Standalone |
SSPD[axis]=[newspeed] |
SSPDM[axis] |
Operating procedure
If there is no change in the previous set data, operation 1 below is not necessary.
- Set the speed range with SSPDM command
- Issue the speed change command
Operating conditions
- While operating at HSPD (not decelerating)
- Buffer operation must disable
- S-curve acceleration/deceleration mode must disable
Related commands
On-the-fly Target Position Change (Target position change)
On-the-fly target position change can be achieved using the T[axis][newtarget] command, and changes the final destination of the motor while the motor is moving. If the motor has already passed the new target position, it will reverse direction when the target position change command is issued.
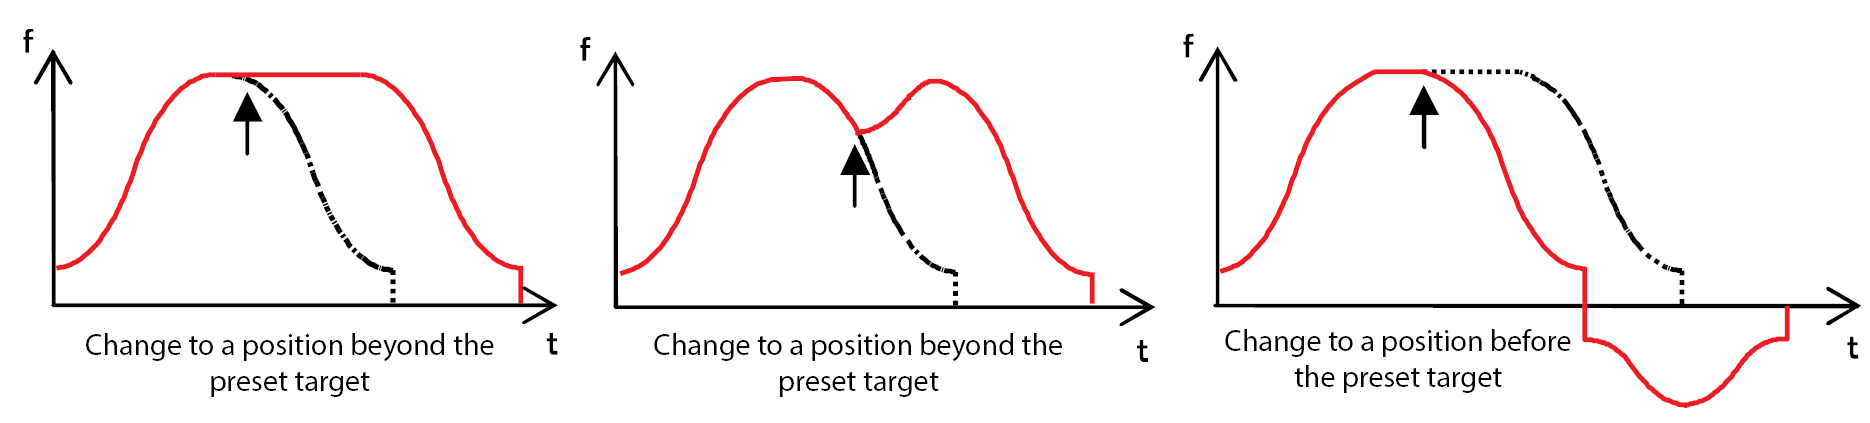
An on-the-fly target position change command is only valid if the specified axis is performing an individual position move. An interpolated, jogging, or homing move will not accept an on-the-fly target position change command.
In ABS mode, the target change is to the absolute position from the homed zero point. In INC mode the target change is to the incremental position from the original move start point.
|
ASCII |
|
|
Standalone |
- |
Operating procedure
There is no predetermined procedure. On-the-fly target position change commands can be issued while the axis is moving.
Operating conditions
While operating with the set value of HSPD (not decelerating)
Related commands