2.1 General Connections and Setup
All commands described in this section are ASCII commands unless specified as standalone commands. ASCII commands are used when communicating over USB or serial communication. Standalone commands are used when writing a standalone program to the Commander core. Not every ASCII command is supported in standalone operations.
In this section:
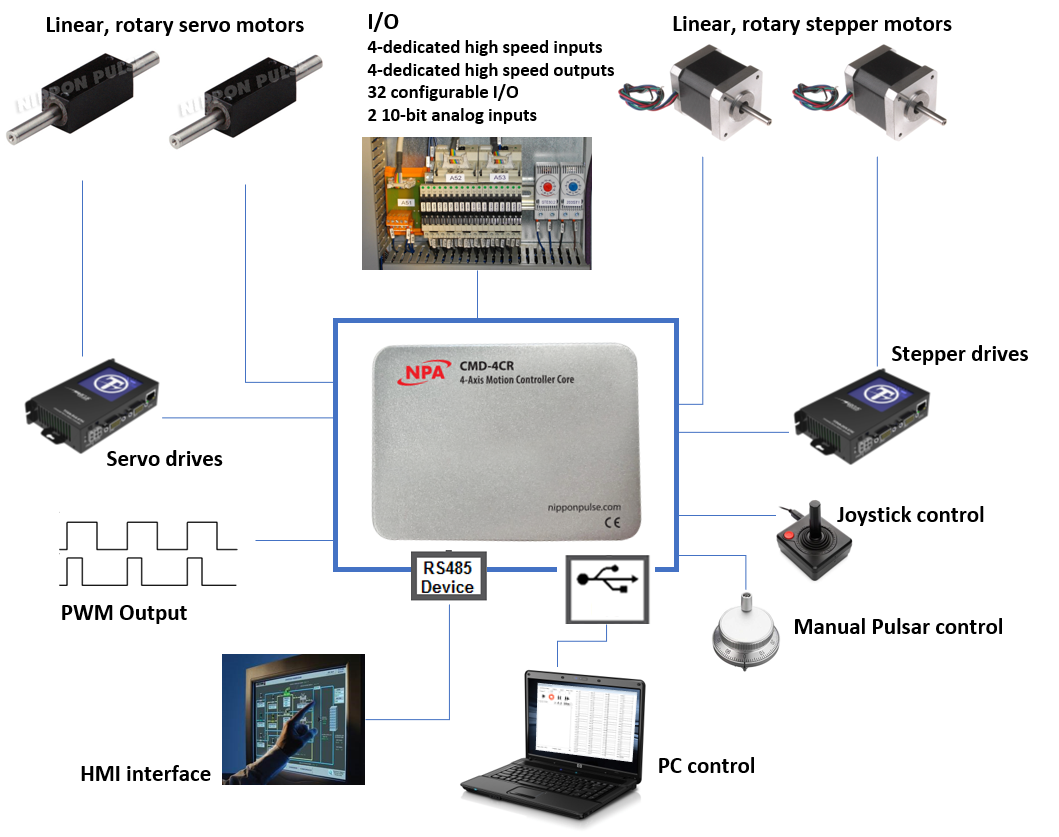
- Connect multiple Commander cores in a system
Commander controllers allow up to 64 devices to be connected to the same host. - Motor interface
Commander controllers are designed to be a master controller for both stepper and digital servomotors and their drivers. - External Connections
Commander controllers include several types of inputs/and outputs which are not directly related to the motion of the motor. - Motion Profile
Commander controllers use an S-curve acceleration profile by default. - Power-on settings
Commander controllers can set and store the default power-on value for the digital outputs and standalone programs. - System settings
The Commander series of controllers can set and store system settings. - Flash Memory
Commander controllers have a built-in flash memory that allows it to store system settings.