2.1.2.1 Stepper
Stepper motor operation is synchronized by command pulse signals output from the Commander controller (it follows the pulses). The stepper driver requires the pulse (speed command), direction (direction command), and enable connected. An encoder connection is not required unless the StepNLoop function is used; however, there are advantages if an encoder is connected.
The pulse (PUL) and direction (DIR) communicate the speed and direction in real-time to the drive. The polarity and output mode of these signals is set with the POL[axis](Bit0~2).
The enable (EO) output is most often used to turn the motor excitation circuit ON/OFF. But, if not required by the driver or application, it can be used as a general-purpose output. The polarity of this output is set with the POL[axis](Bit9).
The figure shows connection examples for open loop and closed loop stepper systems.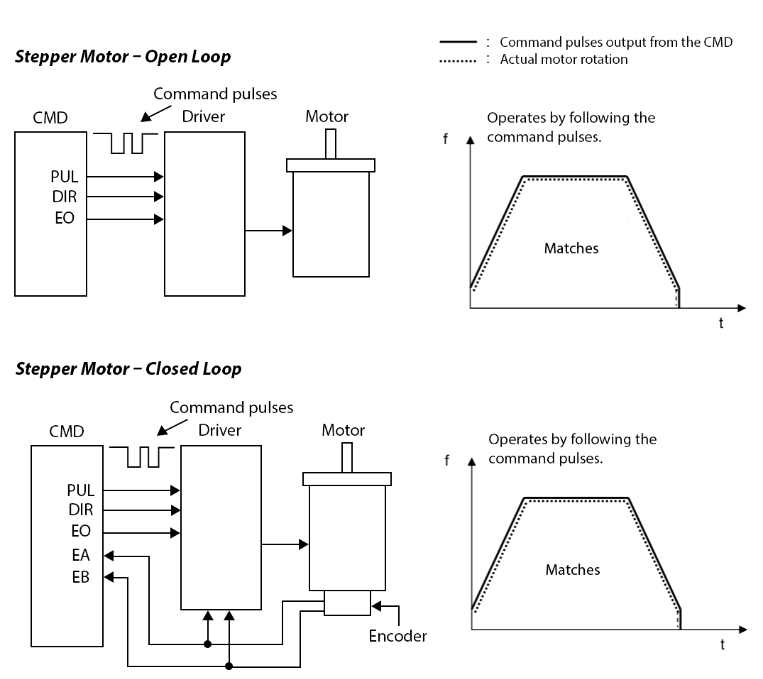
See Basic Motion Control: Stepping Motors for more information
< Previous | Section Home | Home | Next >